Tecnológico de Monterrey (ITESM) ↗
B.S. in Robotics and Digital Systems Engineering · Robotics & Digital Systems Engineering
Monterrey, Mexico · Aug 2022 – Dec 2026
Average: 98/100 · Top 1% · GPA: 4.0/4.0
About
My degree combines robotics, software, electronics, embedded systems, control, and artificial intelligence. The program has let me move repeatedly between theory and physical implementation — from kinematics and control to perception, autonomous navigation, embedded firmware, and complete robotic-system integration.
Relevant Coursework
Intelligent Robotics, Computer Vision, Control Systems, Data Structures & Algorithms, Kinematics & Dynamics
Achievements
- Top 1% GPA recognition, School of Engineering & Sciences.
- 3rd Place, Expo Ingenierías 2023 — SafeSpace.
- Received a full scholarship from Tecnológico de Monterrey to attend the Beijing Institute of Technology International Summer Program.
Key Projects
Manchester Robotics
Monterrey, Mexico
Self-Driving Car — Manchester Robotics
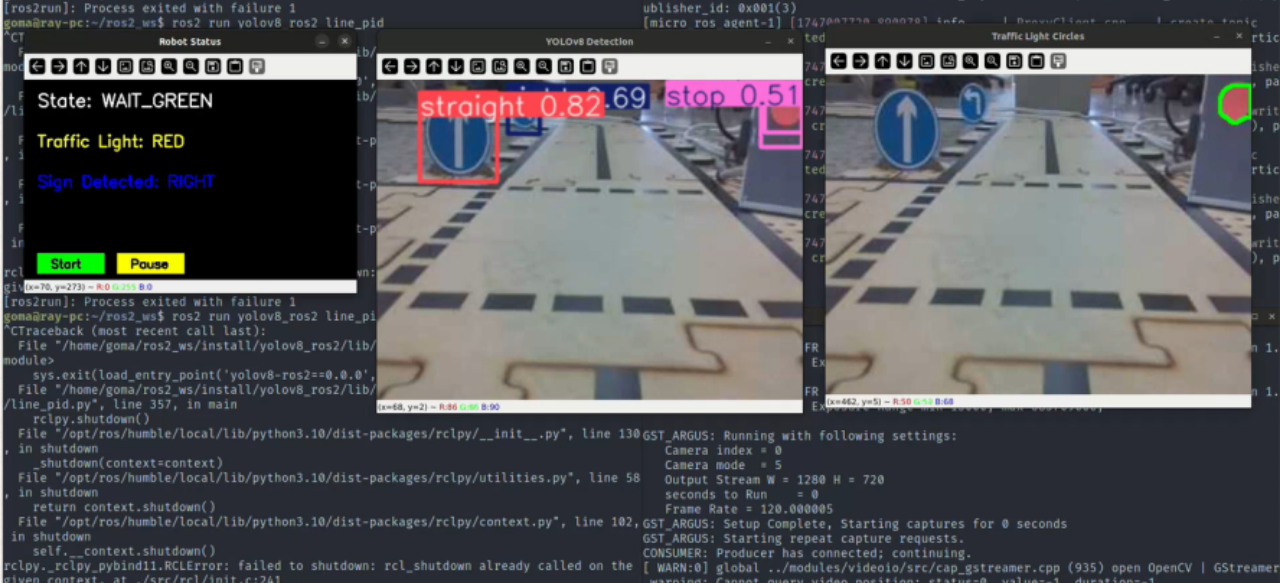
Scaled autonomous car combining ROS 2, Jetson Nano, PID line following, traffic-light perception, YOLOv8 traffic-sign detection, and state-based driving.
Tecnológico de Monterrey
Monterrey, Mexico
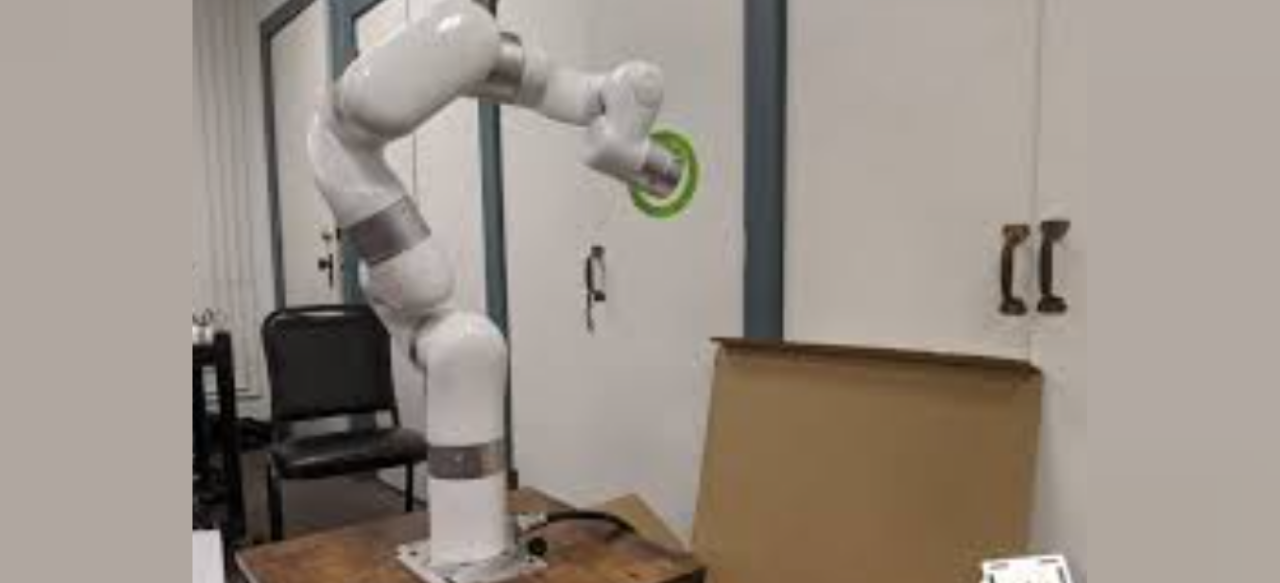
ROS 2 Object Tracking with PointNet and xArm 6
Perception-to-action system combining RGB-D sensing, a custom PointNet classifier, ROS 2 visual tracking, and physical xArm 6 control.
John Deere
Monterrey, Mexico
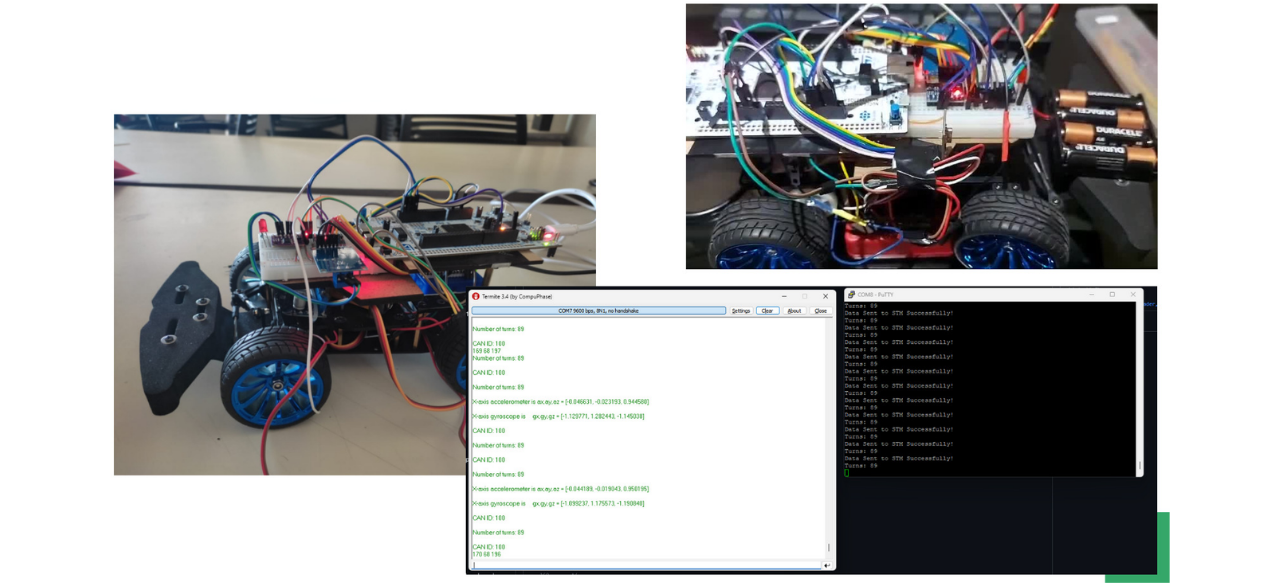
Autonomous Tractor Navigation — John Deere
STM32-based autonomous scale tractor using camera, encoder, and IMU feedback, wireless target coordinates, embedded communication, and closed-loop control.
John Deere
Monterrey, Mexico
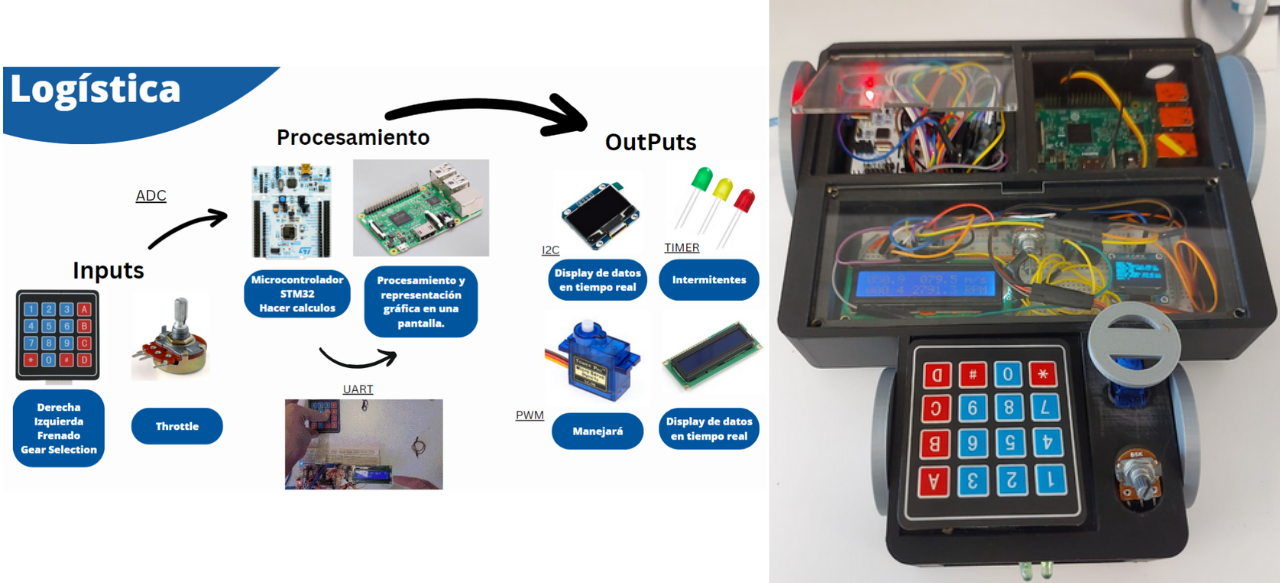
Embedded Tractor Telemetry & Control — John Deere
STM32 + Raspberry Pi embedded system for a John Deere-sponsored challenge, combining real-time task scheduling, bidirectional UART telemetry, transmission-model execution, CSV logging, and a multithreaded Tkinter/Matplotlib dashboard with software-controlled throttle simulation.
Tecnológico de Monterrey (ITESM)
Monterrey, Mexico
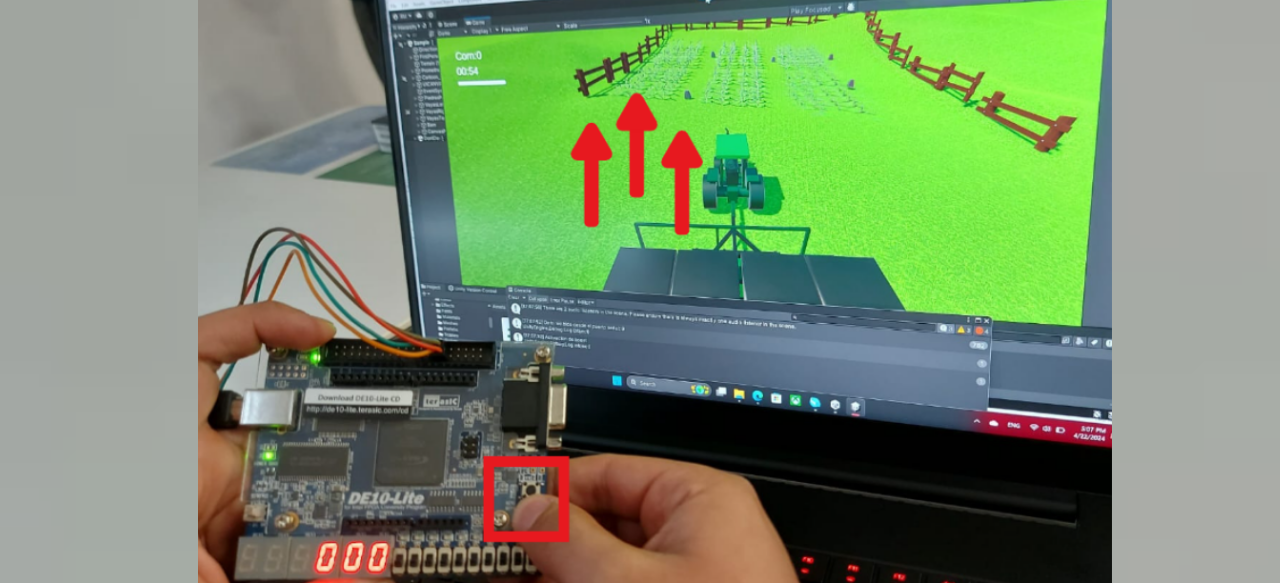
FPGA Tractor Simulator with Unity — John Deere
Bidirectional FPGA-to-Unity tractor simulator built for a John Deere collaboration, using a Terasic DE10-Lite (VHDL and Assembly), accelerometer-based steering, and serial telemetry that returns live simulation state to the board's seven-segment displays.