Robotics & AI Engineer
Hi, I'm Raymundo.
I build intelligent robotic systems that connect perception, navigation, manipulation, AI, and embedded control into complete autonomous systems. I'm completing my B.S. in Robotics and Digital Systems Engineering at Tecnológico de Monterrey, with research and engineering experience across Japan, South Korea, China, Canada, and Mexico.
I recently completed a robotics research internship at the CNRS-AIST Joint Robotics Laboratory in Tsukuba, Japan. I'm open to full-time robotics opportunities starting in 2027.
Projects
Selected work across autonomous navigation, perception, manipulation, embedded systems, and AI — built in simulation and on real hardware.
National Institute of Advanced Industrial Science and Technology (AIST)
Tsukuba, Japan
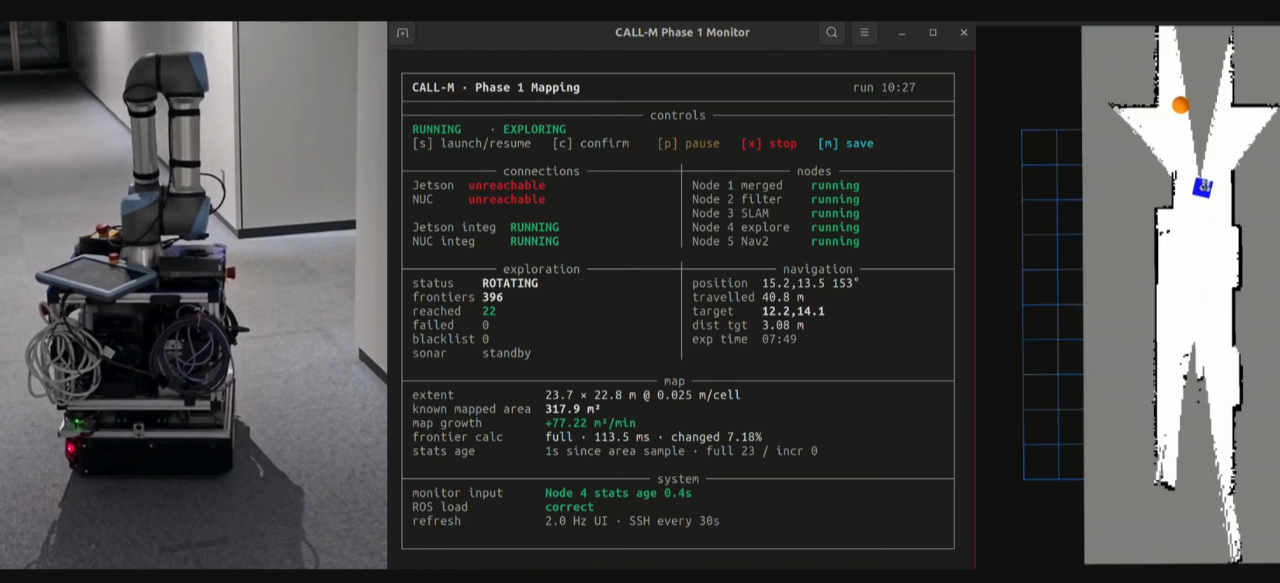
Autonomous Mapping — CALL-M Mobile Manipulator
Modular ROS 2 autonomous-mapping architecture for CALL-M built around three contributions — supervised mission orchestration, reusable exploration management, and static–dynamic obstacle filtering — validated in simulation and on the physical robot.
National Institute of Advanced Industrial Science and Technology (AIST)
Tsukuba, Japan
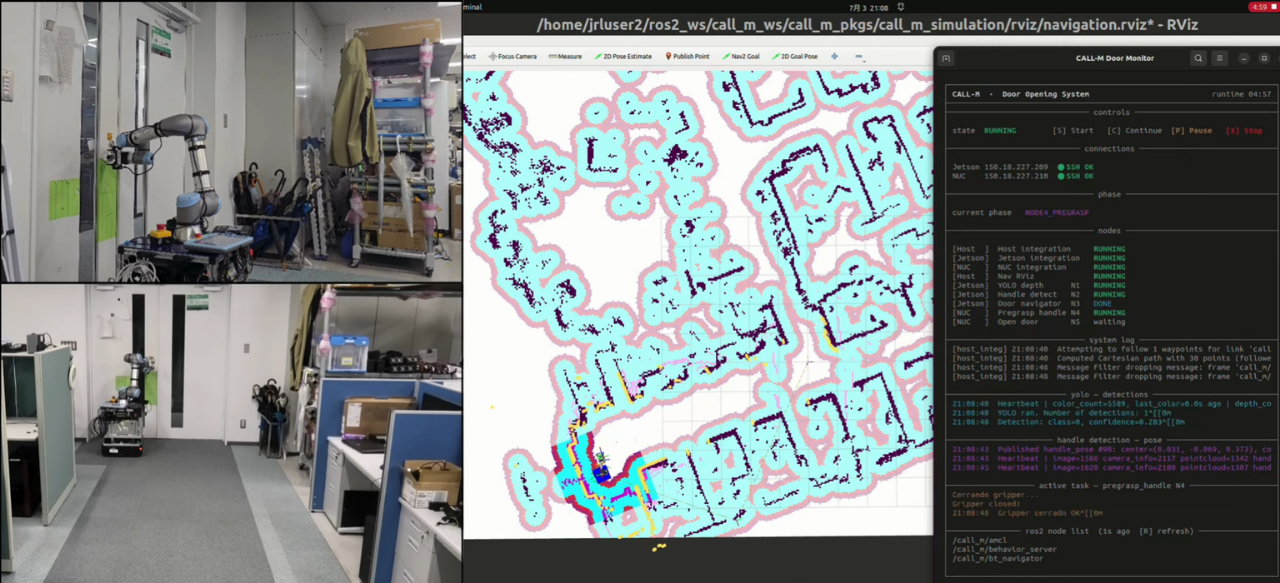
Autonomous Door Opening — CALL-M Mobile Manipulator
End-to-end perception, navigation, and manipulation pipeline that lets CALL-M find a door, localize its handle in 3D, align its base, and execute the opening motion — evaluated across 20 real-robot trials under nominal, distance-varied, and height-varied conditions.
Manchester Robotics
Monterrey, Mexico
Self-Driving Car — Manchester Robotics
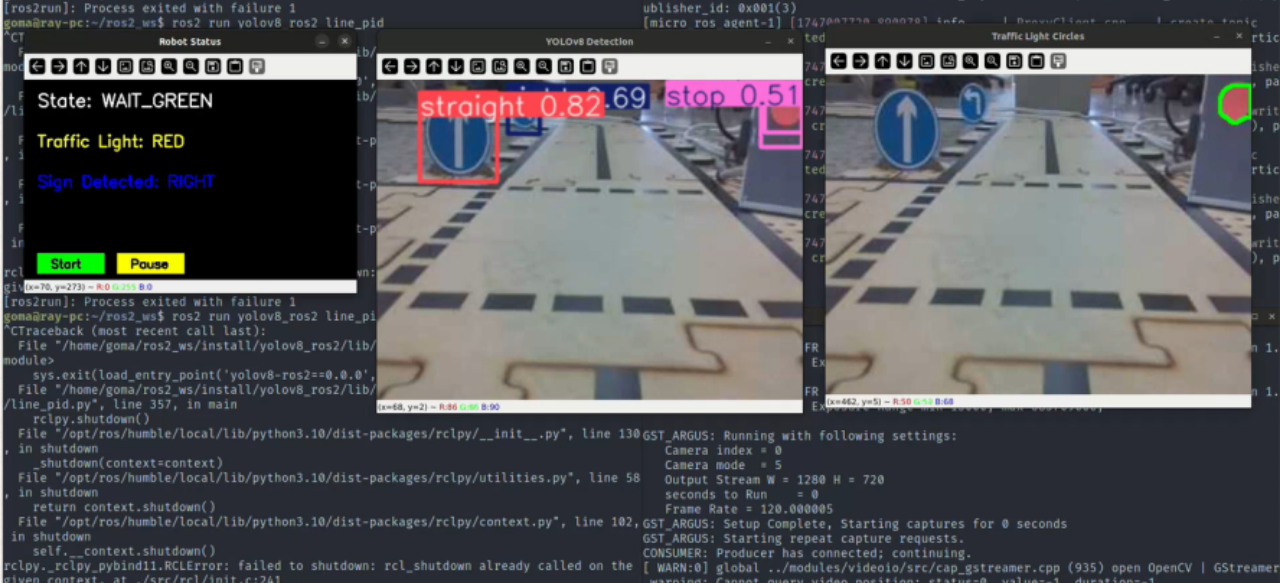
Scaled autonomous car combining ROS 2, Jetson Nano, PID line following, traffic-light perception, YOLOv8 traffic-sign detection, and state-based driving.
Tecnológico de Monterrey
Monterrey, Mexico
ROS 2 Object Tracking with PointNet and xArm 6
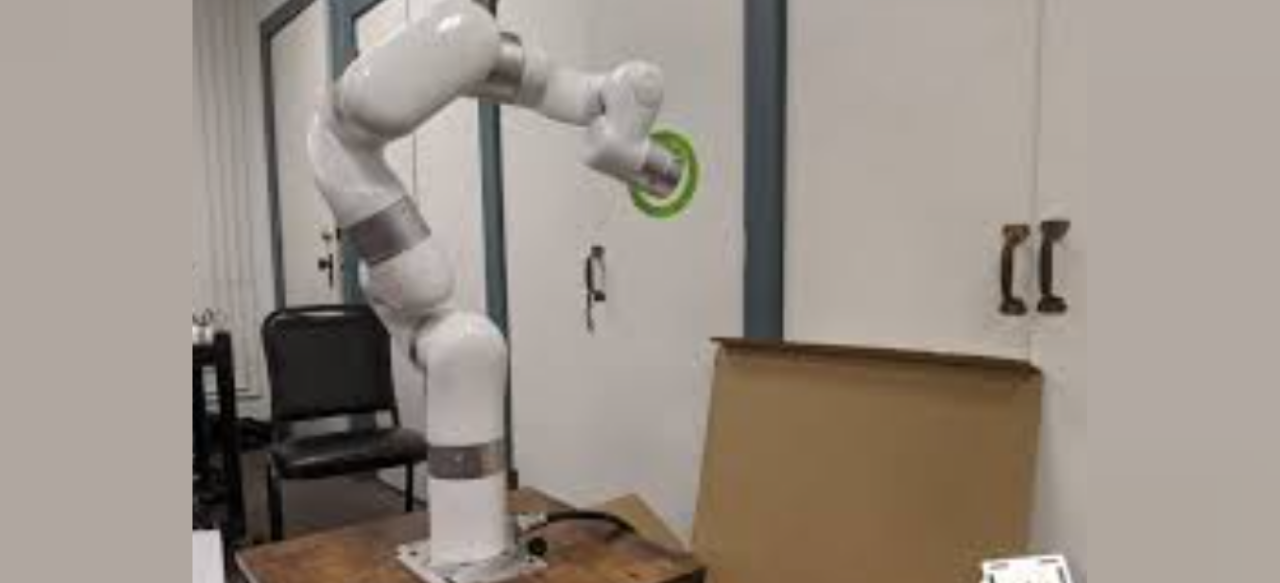
Perception-to-action system combining RGB-D sensing, a custom PointNet classifier, ROS 2 visual tracking, and physical xArm 6 control.
John Deere
Monterrey, Mexico
Autonomous Tractor Navigation — John Deere
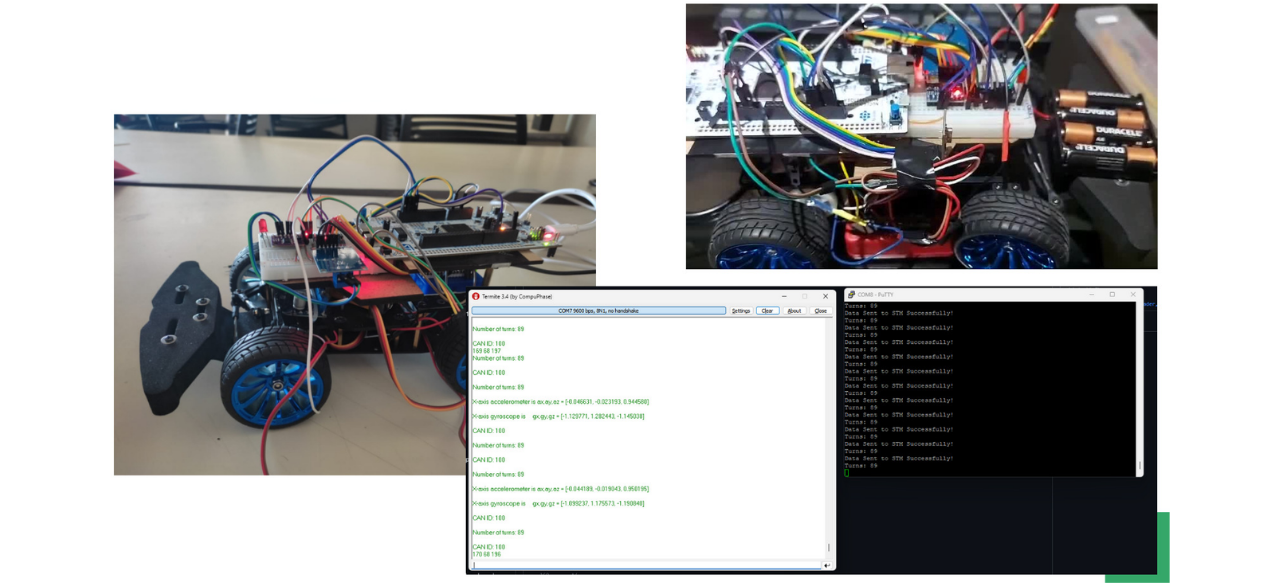
STM32-based autonomous scale tractor using camera, encoder, and IMU feedback, wireless target coordinates, embedded communication, and closed-loop control.
All Projects
Explore all 10 projects with full technical details
View all →Work Experience
Experience across robotics research, industrial automation, software, and technology integration.
Robotics Research Intern
AIST – National Institute of Advanced Industrial Science and Technology
Tsukuba, Japan
- ▸ Developed autonomous mapping, dynamic-environment perception, navigation, and mobile-manipulation systems for CALL-M, with work spanning ROS 2 architecture, SLAM, Nav2, RGB-D/LiDAR perception, exploration, manipulation, real-robot validation, and research writing.
- ▸ Authored 2 research papers as first author and contributed to a third as co-author during the internship.
Robotics Engineer Intern
Smart Factory MTY
Monterrey, Mexico
- ▸ Commissioned, diagnosed, repaired, and integrated UR, xArm, Baxter, and ABB YuMi robots. Designed and fabricated a custom gripper that increased production throughput by 30%, while maintenance and root-cause work helped reduce downtime by 20%.
Systems & Data Automation Engineer
Tecnológico de Monterrey (ITESM)
Monterrey, Mexico
- ▸ Automated databases and compliance workflows supporting university–government contracts across 50 campuses and $5.3M in projects, reducing manual work for 100+ employees and improving document processing time by 21%.
Freelance Technology Specialist
Self-Employed
Mexico / United States
- ▸ Delivered technology and automation solutions for 50+ SME clients in Mexico and the USA, translating operational problems into practical technical solutions.
Computer Programmer (Part-time)
CIBRUC
Monterrey, Mexico
- ▸ Built an interactive simulation/game in Godot for online hosting and licensing, with responsibility for application logic, UI/UX, and production-focused iteration.
Education
Robotics engineering at Tecnológico de Monterrey, complemented by international study in AI, embedded systems, electronics, and technical communication.
Tecnológico de Monterrey (ITESM)
B.S. in Robotics and Digital Systems Engineering
Robotics & Digital Systems Engineering
Monterrey, Mexico
Average: 98/100 · Top 1% · GPA: 4.0/4.0
University of Seoul (UOS)
Exchange Program
AI, Embedded Systems & Solid-State Electronics
Seoul, South Korea
Grade: A+
Beijing Institute of Technology (BIT)
Summer Program
Electronics & Intelligent Systems
Beijing, China
Grade: A+
University of Waterloo
Summer Program
Academic Communication & Cross-Cultural Studies
Waterloo, Canada
Grade: A+
Research & Invited Talks
Research in autonomous mapping, dynamic-environment perception, mobile manipulation, and intelligent robotic systems.
Neuromorphic Computing and Memristor-Based Devices in Intelligent Robotics
Guest Lecturer · University of Seoul
Seoul, South Korea
Invited by the engineering faculty to deliver a lecture to an international engineering cohort on neuromorphic computer architectures, memristor-based devices, and the role of specialized hardware in energy-efficient AI systems.
A Supervised ROS 2 Architecture for Autonomous Mapping: Modular Exploration-Management Framework
First Author · CNRS-AIST Joint Robotics Laboratory
Tsukuba, Japan
Presents a modular ROS 2 software architecture for autonomous mapping in unknown and dynamic environments. The exploration-management framework handles frontier evaluation, navigation-goal supervision, failure recovery, progress monitoring, and mission completion while remaining configurable for Nav2-compatible robots.
This paper presents a modular ROS 2 architecture for autonomous mapping in mobile robots operating within unknown and dynamic indoor environments. The proposed system integrates multimodal scan fusion, a static–dynamic obstacle-filtering module, SLAM-based map construction, frontier-based exploration, and Nav2-based navigation, coordinated by a program manager that governs the mission from distributed launch through coordinated termination. Beyond this supervised software system, the architecture is organized around a modular ROS 2 exploration-management framework that extends beyond frontier detection to govern candidate evaluation, navigation-goal supervision, failure recovery, and mission completion. Requiring only an occupancy-grid map, robot-pose information through TF, and a Nav2-compatible navigation interface, the framework may be adopted by compatible ROS 2 mobile-robot stacks through external configuration, without modification of its underlying implementation. The complete system is validated in simulation and on the physical CALL-M mobile manipulator.
A ROS 2 Static–Dynamic Obstacle Filtering Framework for Robust Mapping in Dynamic Environments
First Author · CNRS-AIST Joint Robotics Laboratory
Tsukuba, Japan
Develops a reusable preprocessing framework that separates persistent environmental structure from moving observations before mapping, while preserving dynamic obstacles for real-time navigation, tracking, and collision avoidance.
This work presents a modular ROS 2 framework for separating static environmental structure from dynamic obstacles in LaserScan-based robotic mapping and navigation. The framework processes unified multimodal range observations to distinguish persistent structures from transient measurements, providing a static scan for SLAM-based map construction and a dynamic scan for real-time obstacle avoidance. In addition, dynamic observations may be tracked to estimate obstacle motion while preserving compatibility with conventional ROS 2 LaserScan interfaces. The approach is designed as a reusable preprocessing layer for mobile robots operating in dynamic indoor environments, improving map consistency while retaining moving obstacles for navigation and collision avoidance.
An Integrated Perception, Navigation, and Manipulation Pipeline for Semi-Autonomous Door Opening with a Mobile Manipulator
Second Author · CNRS-AIST Joint Robotics Laboratory
Tsukuba, Japan
Presents an end-to-end mobile-manipulation pipeline combining door perception, LiDAR-based Nav2 approach, RGB-D handle localization, base alignment, pre-grasp positioning, grasp execution, and physical door opening on CALL-M. Evaluated in 20 real-robot trials; in the 10 nominal trials, upstream perception, navigation, localization, alignment, and pre-grasp stages succeeded 10/10, while complete door opening succeeded 8/10.
Autonomous door opening is a key capability for service robots. It requires integration of perception, navigation, localization, and manipulation. This paper presents a semi-autonomous door-opening pipeline for a mobile manipulator. The system requires manual initialization of the robot pose in RViz; it autonomously detects and approaches the door, estimates the 3D handle position, aligns the mobile base, performs the pre-grasp positioning, and executes handle manipulation and door opening. The system was evaluated on a real mobile manipulator in 20 trials: 10 nominal operation trials, 5 trials with varying initial robot-to-door distance, and 5 trials varying initial end-effector height. In nominal condition, door perception, navigation, 3D localization, alignment, and pre-grasp positioning succeeded 10/10, while complete door opening succeeded 8/10. The system successfully handled the initial robot-to-door distance in four of five trials. However, changes in the initial end-effector height reduced performance, completing only one of five trials. Failures occurred mainly in the contact and interaction between the handle and the gripper. Physical handle manipulation is the main limitation of the current system.
Awards & Recognition
Selected academic honors, international recognition, and engineering competition results.
Student Representative & Outstanding Performance Recognition
Beijing Institute of Technology (BIT)
Beijing, China
Recognized for strong performance in the international Electronics Engineering program and selected to deliver the closing ceremony speech representing the international cohort.
Top 1% GPA — School of Engineering & Sciences
Tecnológico de Monterrey (ITESM)
Monterrey, Mexico
Recognized by Tecnológico de Monterrey for ranking among the top 1% of engineering students by academic average.
3rd Place — Expo Ingenierías 2023
Tecnológico de Monterrey (ITESM)
Monterrey, Mexico
Awarded third place for SafeSpace, a home-safety system for older adults combining facial recognition, environmental sensing, automation, and remote monitoring.
Skills
Technical stack used across robotics research, autonomous systems, embedded development, perception, and real hardware.
Languages
Spanish
Native
Native
English
C2
Near-Native
German
B1
Intermediate
Programming
Robotics & Autonomy
Perception & AI
Embedded & Hardware
Software & Engineering
Open to International Robotics Opportunities
I'm graduating in December 2026 and looking for full-time opportunities starting in 2027 across intelligent robotics, autonomous systems, perception, mobile manipulation, AI for robotics, and embedded systems.
Based in Monterrey, Mexico · Open to international opportunities