Projects
Selected robotics projects spanning autonomous navigation, mobile manipulation, computer vision, embedded control, AI, and hardware–software integration.
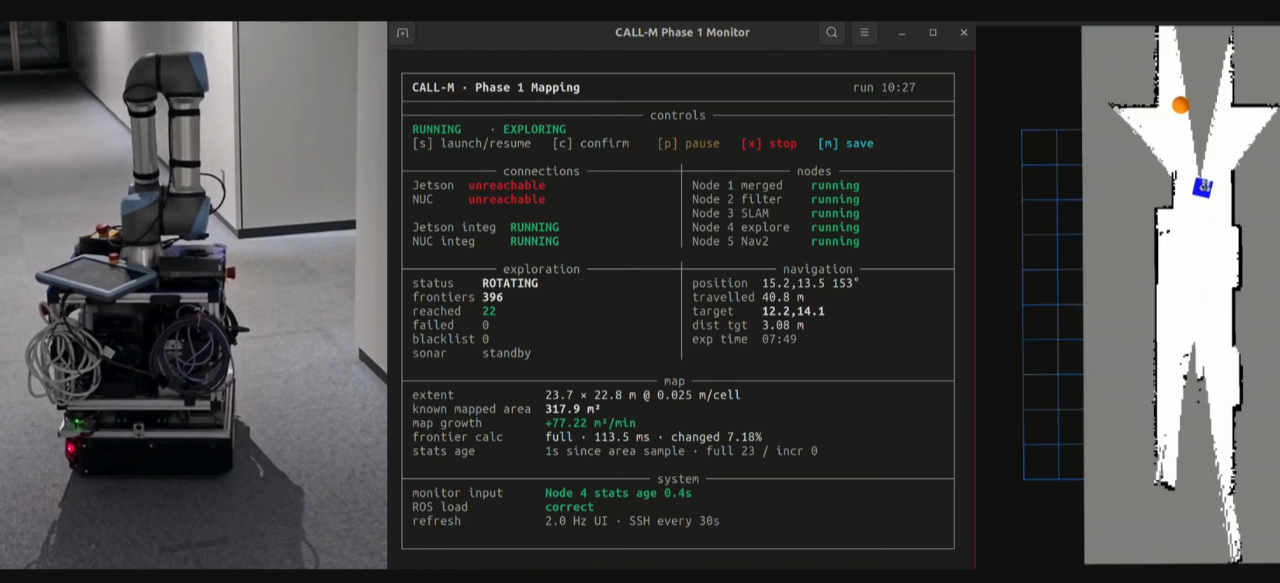 🤖
Autonomous Mapping — CALL-M Mobile Manipulator
Modular ROS 2 autonomous-mapping architecture for CALL-M built around three contributions — supervised mission orchestration, reusable exploration management, and static–dynamic obstacle filtering — validated in simulation and on the physical robot.
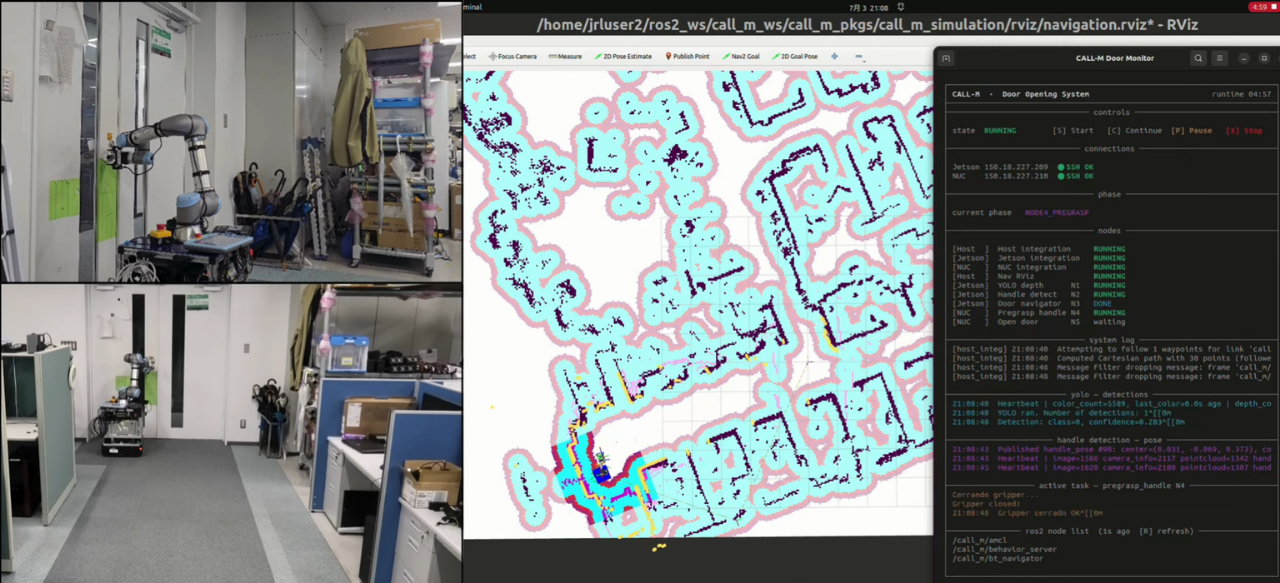 🤖
Autonomous Door Opening — CALL-M Mobile Manipulator
End-to-end perception, navigation, and manipulation pipeline that lets CALL-M find a door, localize its handle in 3D, align its base, and execute the opening motion — evaluated across 20 real-robot trials under nominal, distance-varied, and height-varied conditions.
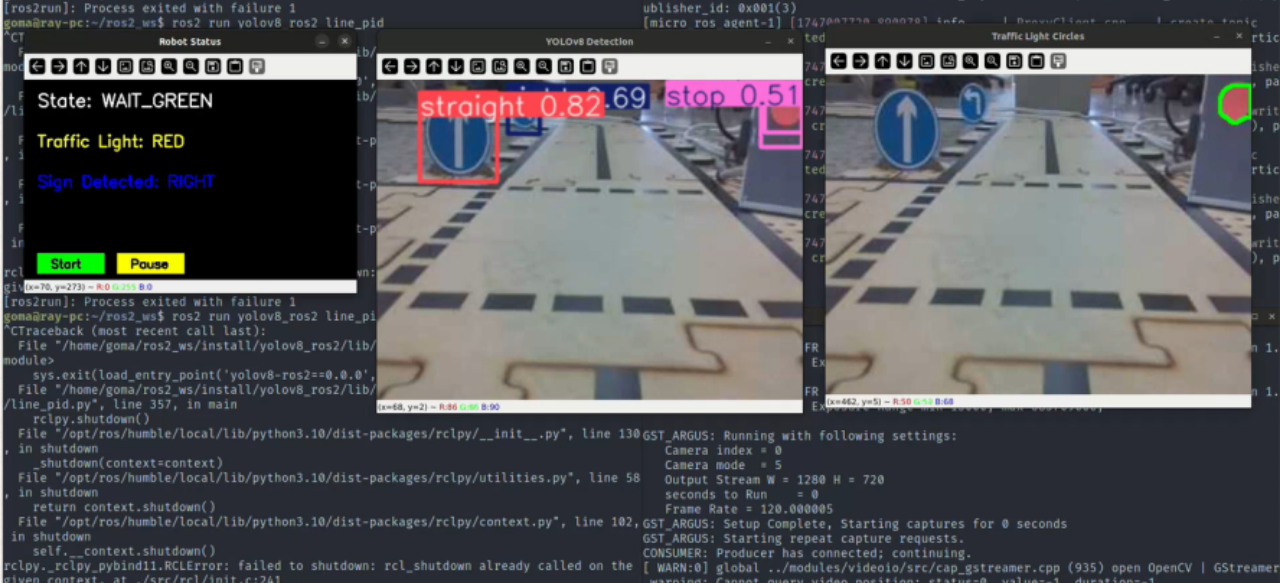 🤖
Self-Driving Car — Manchester Robotics
Scaled autonomous car combining ROS 2, Jetson Nano, PID line following, traffic-light perception, YOLOv8 traffic-sign detection, and state-based driving.
 🤖
ROS 2 Object Tracking with PointNet and xArm 6
Perception-to-action system combining RGB-D sensing, a custom PointNet classifier, ROS 2 visual tracking, and physical xArm 6 control.
 🤖
Autonomous Tractor Navigation — John Deere
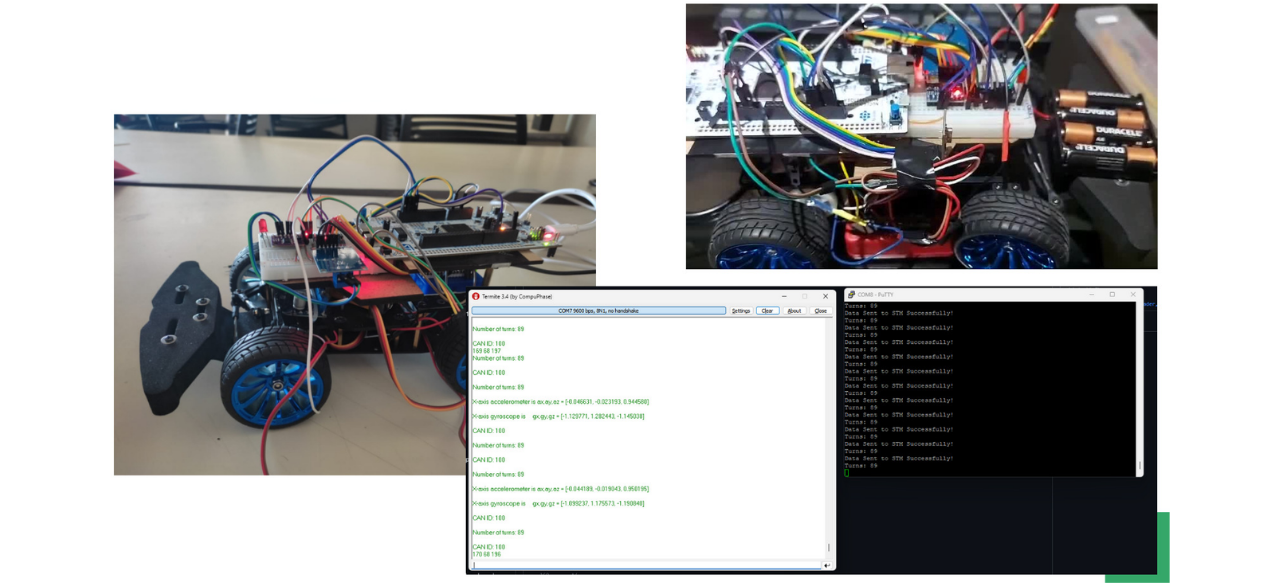
STM32-based autonomous scale tractor using camera, encoder, and IMU feedback, wireless target coordinates, embedded communication, and closed-loop control.
 🤖
Autonomous Face-Tracking Drone
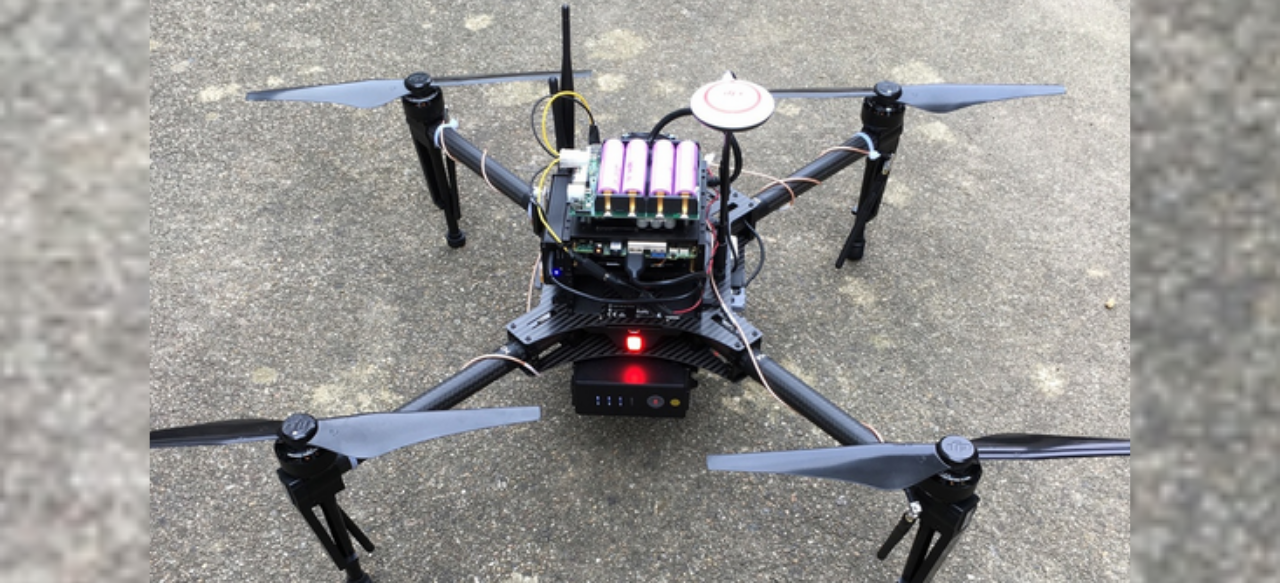
Real-time face-tracking system for a DJI Tello that recognizes a registered person and converts image-space error into yaw, altitude, and forward/backward flight commands, with a multithreaded video pipeline and fail-safe hover behavior.
 🤖
Dual-Elevator Embedded Control System
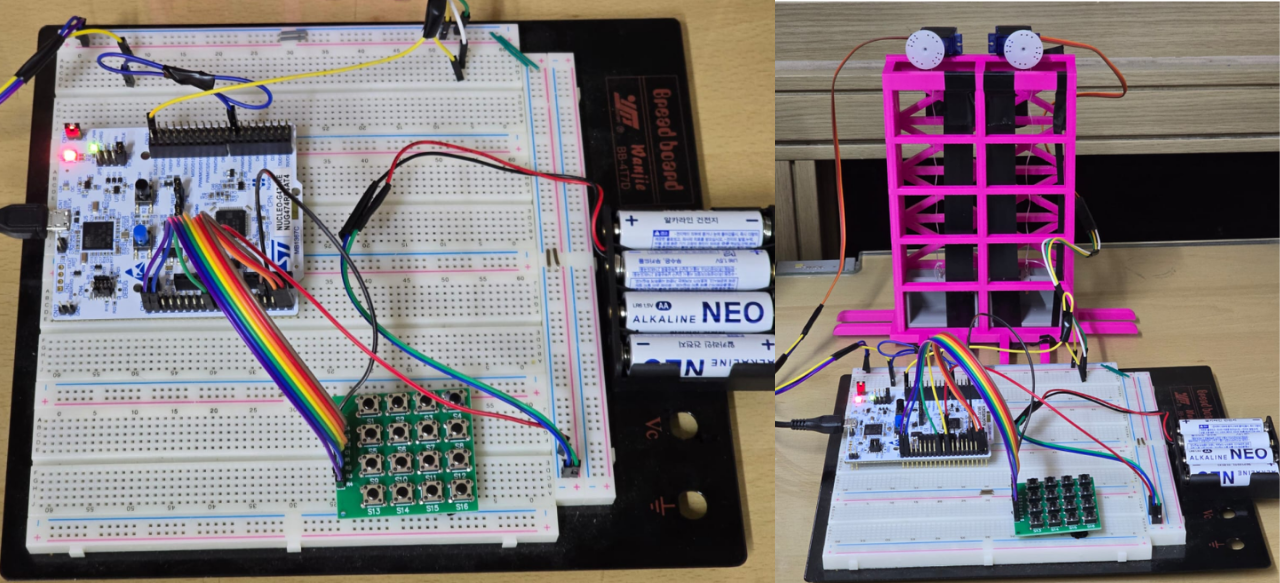
Five-floor, dual-cabin elevator prototype built around an STM32 with independent non-blocking state machines, per-servo PWM calibration, a FIFO request queue, greedy elevator-assignment scheduling, Hall-effect safety sensing, and UART monitoring.
 🤖
IoT Smart Agriculture & Environmental Control
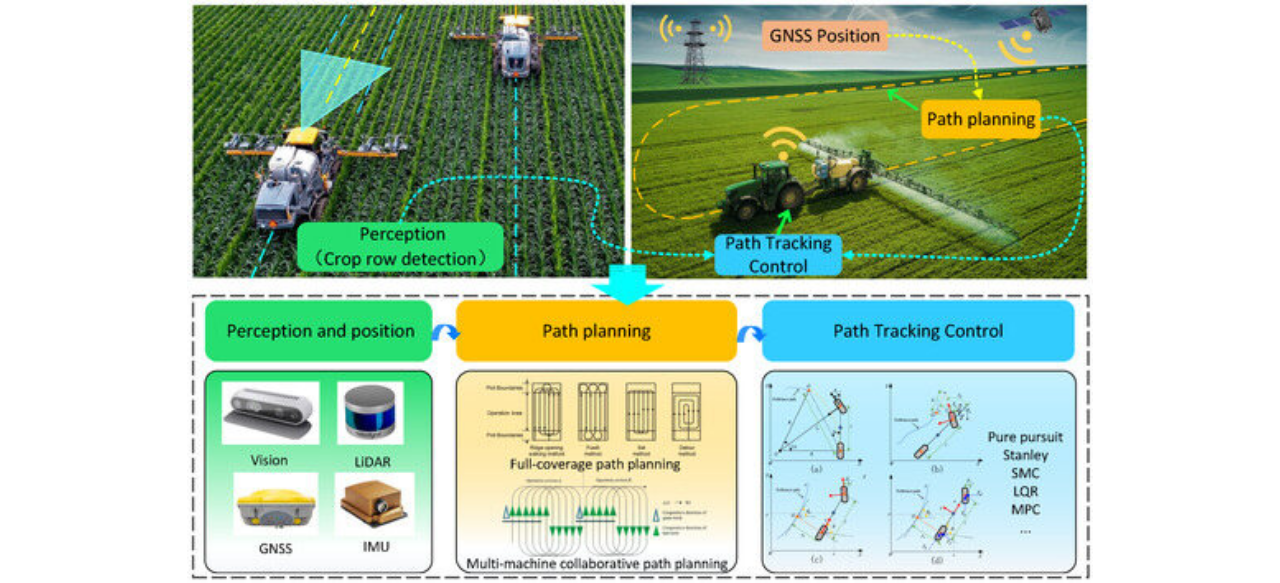
Raspberry Pi-based agriculture prototype combining environmental sensing, automated irrigation and ventilation, and a real-time web dashboard.
 🤖
Embedded Tractor Telemetry & Control — John Deere
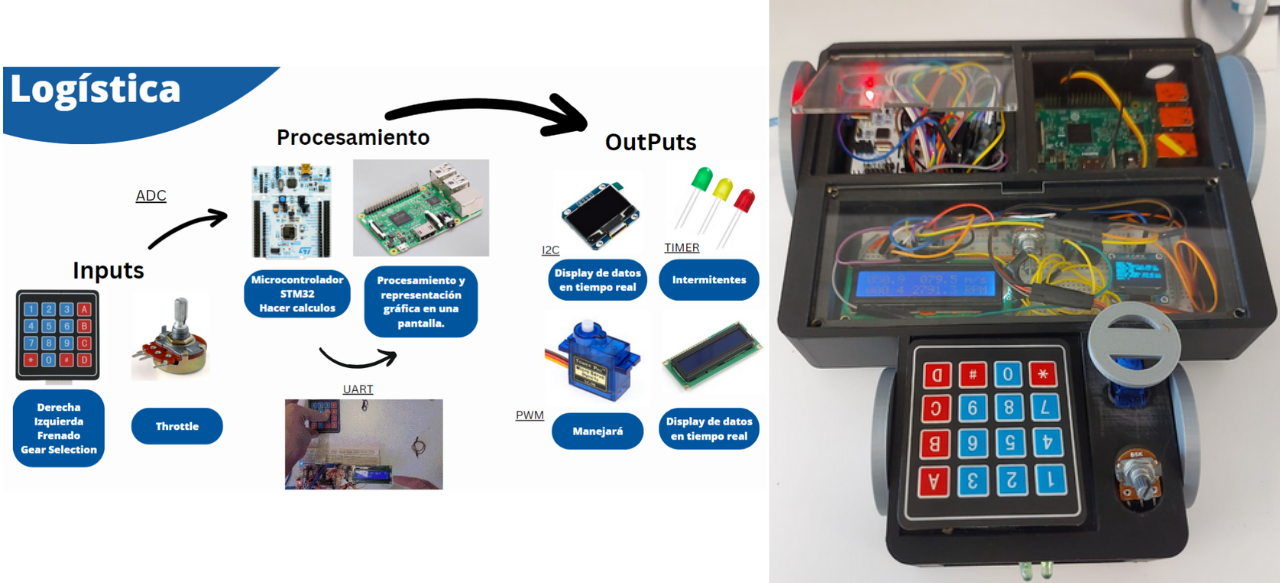
STM32 + Raspberry Pi embedded system for a John Deere-sponsored challenge, combining real-time task scheduling, bidirectional UART telemetry, transmission-model execution, CSV logging, and a multithreaded Tkinter/Matplotlib dashboard with software-controlled throttle simulation.
 🤖
FPGA Tractor Simulator with Unity — John Deere
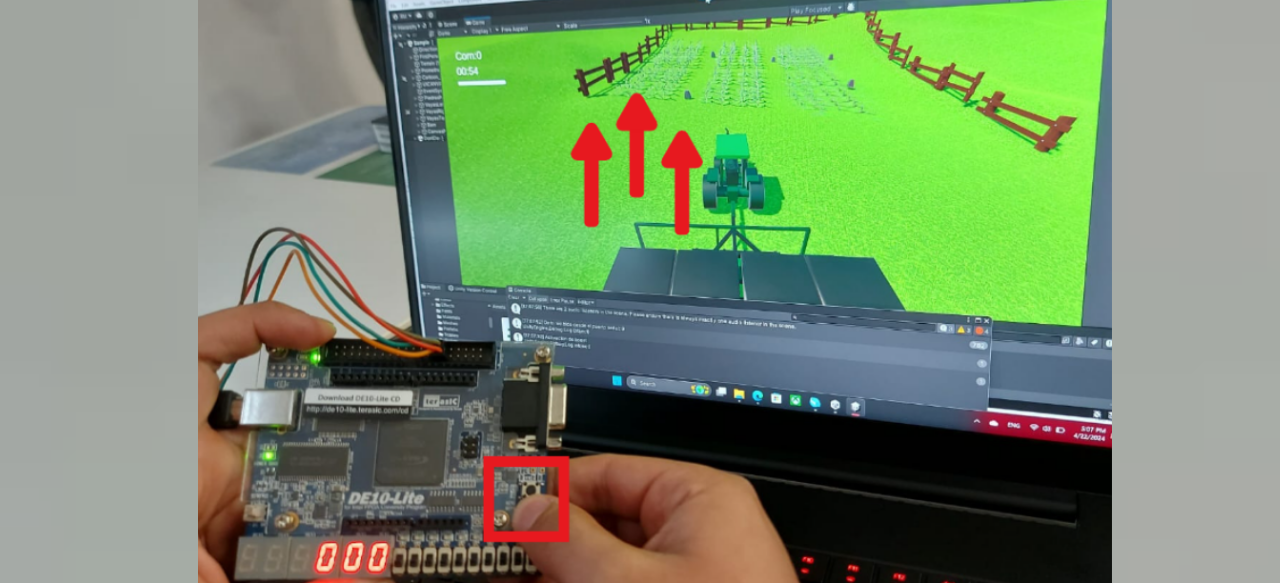
Bidirectional FPGA-to-Unity tractor simulator built for a John Deere collaboration, using a Terasic DE10-Lite (VHDL and Assembly), accelerometer-based steering, and serial telemetry that returns live simulation state to the board's seven-segment displays.